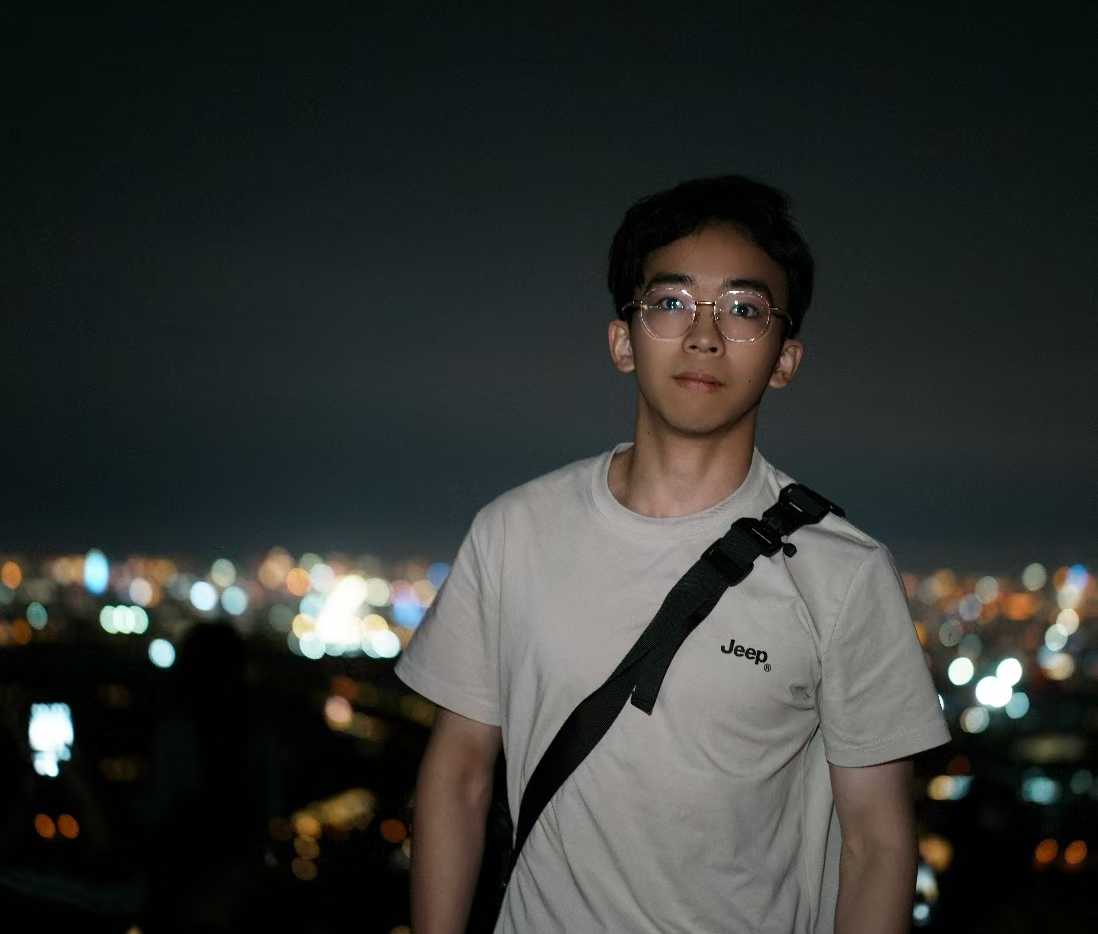
Zhao Jin (S’24) received the B.E. degree in mechanical engineering and a minor in computer science from the Department of Mechanical Engineering and the Department of Computer Science and Technology, respectively, Tsinghua University, Beijing, China, both in 2024. He is currently working toward the Ph.D. degree in mechanical engineering with the Institute of Mechatronics Engineering, Tsinghua University. His research interests include robotics, robotic motion planning, and intelligent control.
Research Interests
- Robotics and control
- Multi-robot safety motion planning
- Humanoid whole-body control
- Inferential statistics
Publications
3 associated published works · View on Research
Distributed Safety-Aware Motion Planning for Dual-Arm Systems via Gaussian Belief Propagation With Application to Catenary Dropper Assembly
IEEE Robotics and Automation Letters
·
Nov 2026
·
doi:10.1109/lra.2026.3732969
Multi-Priority Reactive Motion Control for Safe and Coordinated Dual-Arm Manipulation in Dynamic Environments
IEEE Robotics and Automation Letters
·
Jun 2026
·
doi:10.1109/lra.2026.3686598
Online time-optimal trajectory planning along parametric toolpaths with strict constraint satisfaction and certifiable feasibility guarantee
International Journal of Machine Tools and Manufacture
·
Feb 2026
·
doi:10.1016/j.ijmachtools.2025.104355