HU-LAB

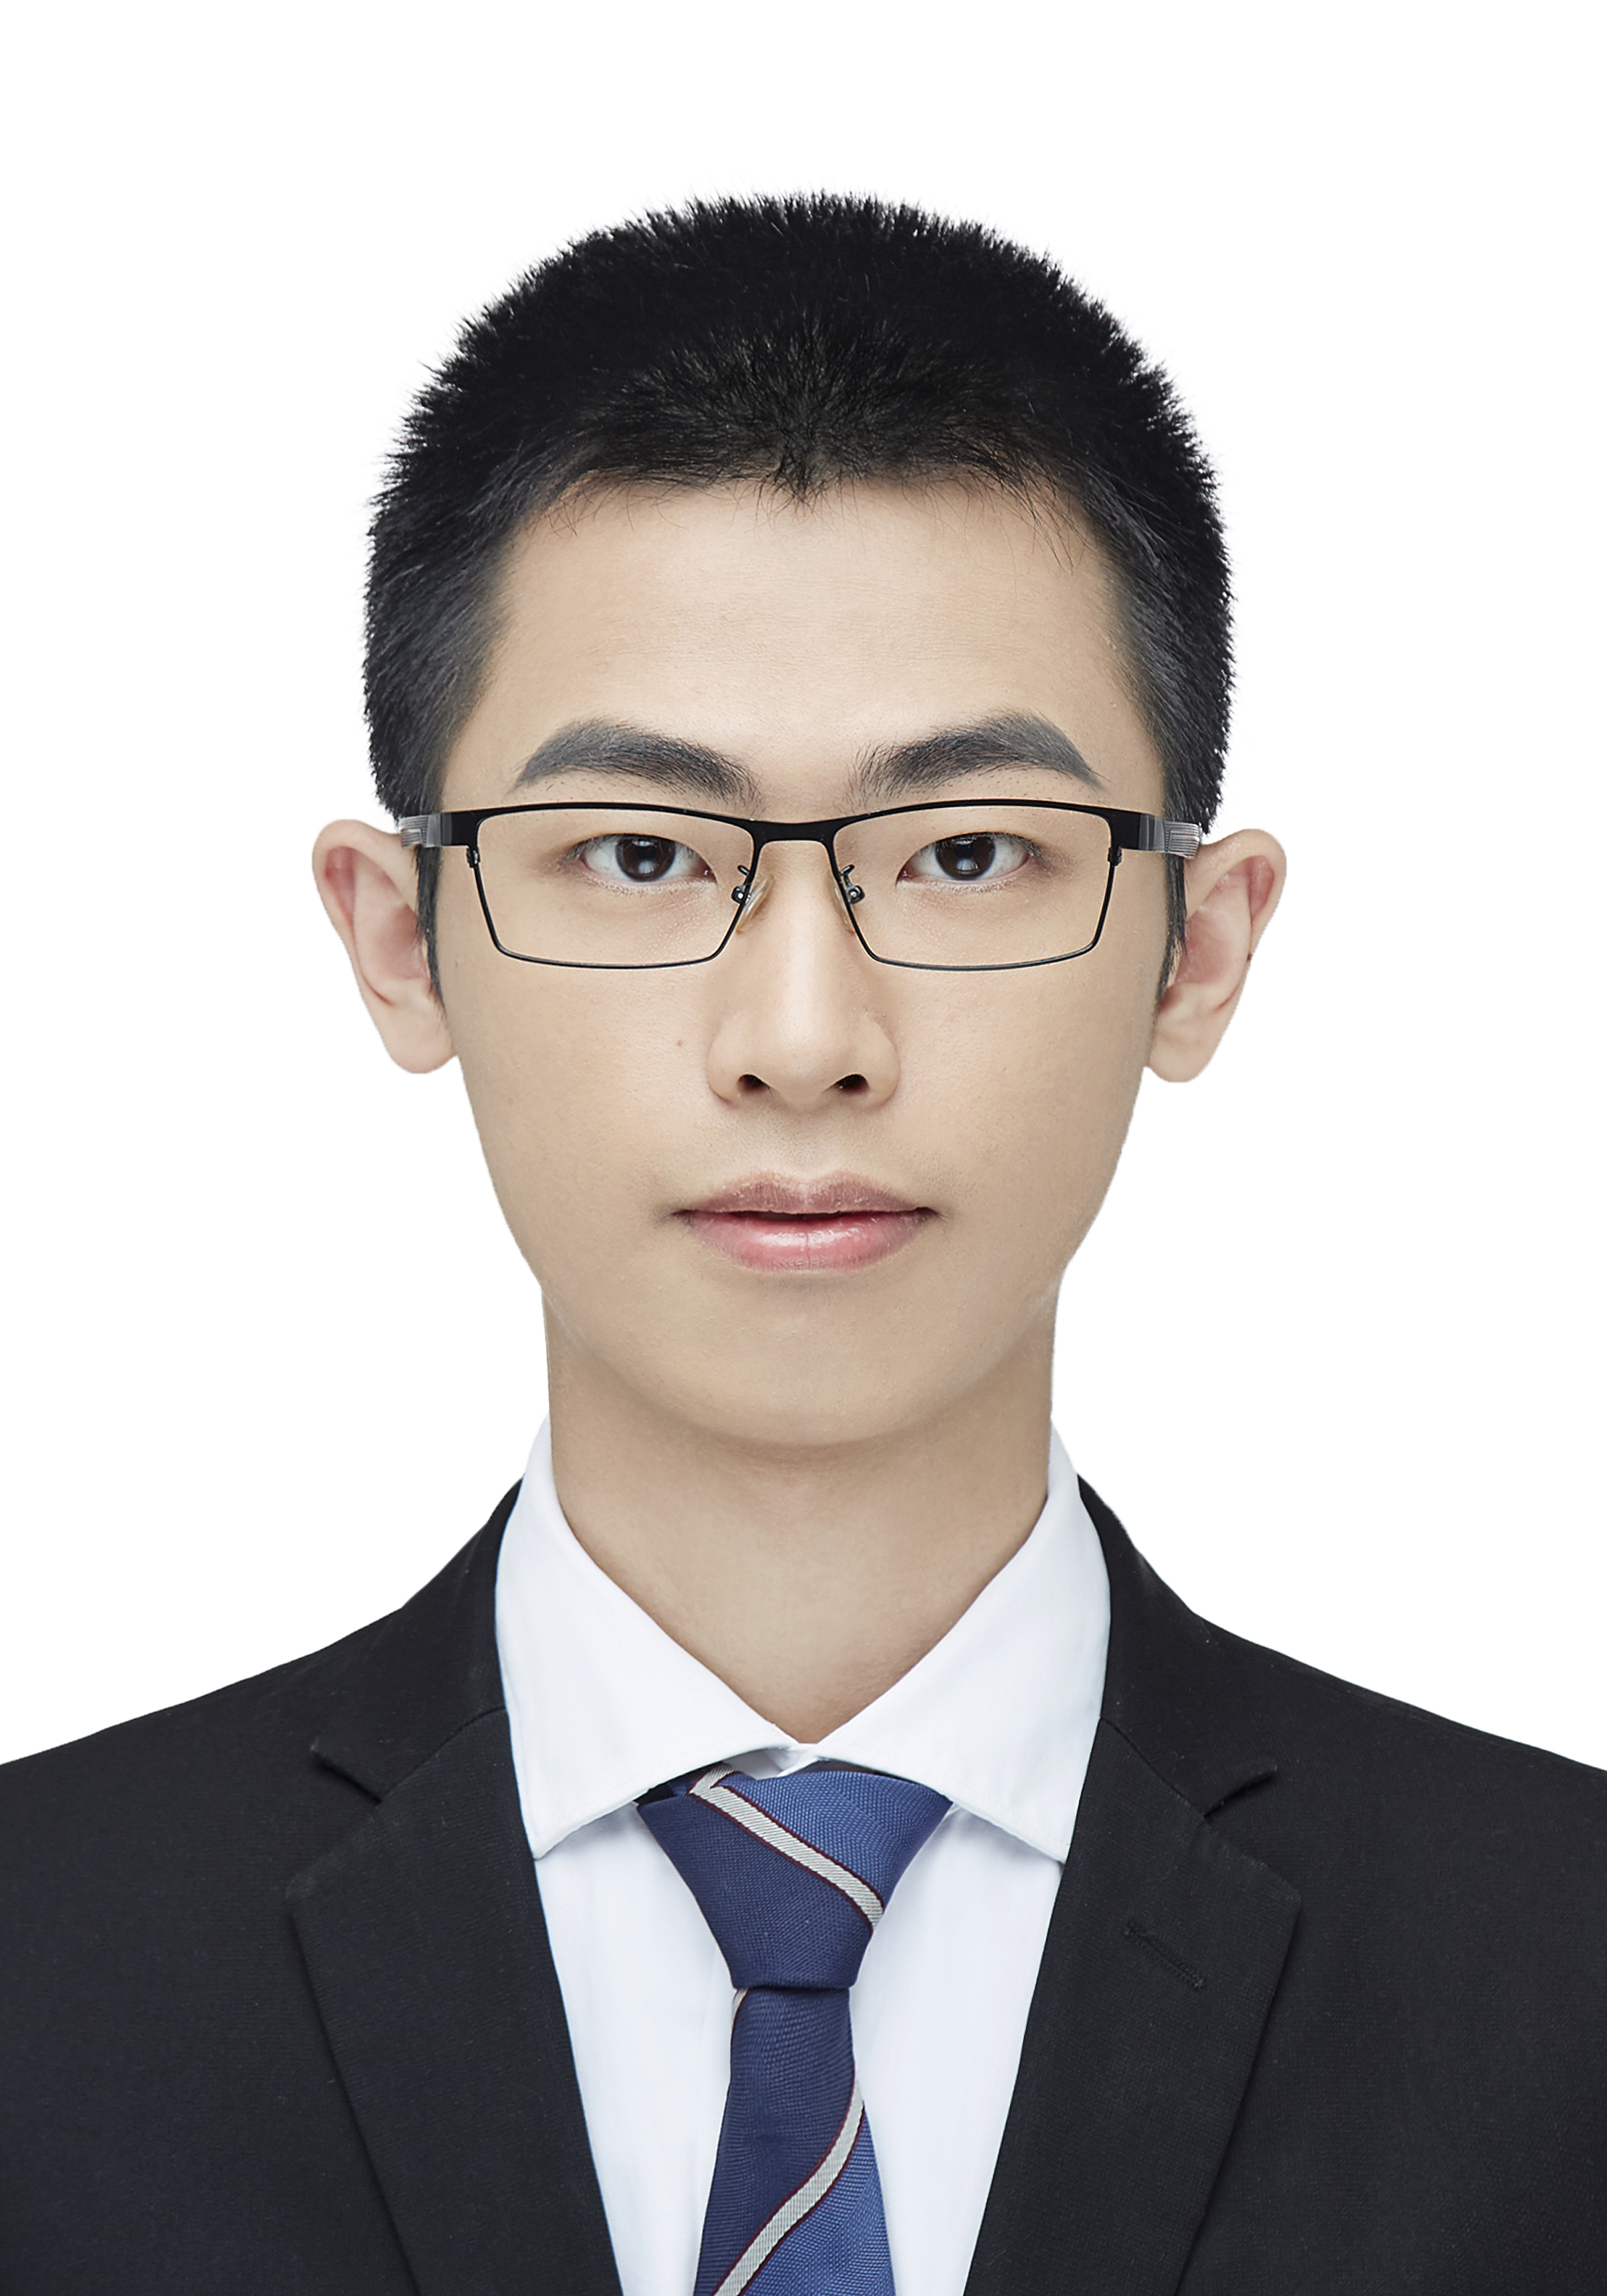
Yunan Wang received the B.E. degree in mechanical engineering from the Department of Mechanical Engineering and the B.S. degree in mathematics, as a second undergraduate degree, from the Department of Mathematical Sciences, Tsinghua University, Beijing, China, in 2022. He is currently working toward the Ph.D. degree in mechanical engineering with the Department of Mechanical Engineering, Tsinghua University. In 2026, he is a Visiting Student Researcher with the Laboratory for Information & Decision Systems, Massachusetts Institute of Technology, Cambridge, MA, USA.

His research interests include optimal control, robotic motion planning, CNC machining, and generative AI.

Mr. Wang was the recipient of the 2021 Top Grade Scholarship for Undergraduate Students of Tsinghua University, the Best Conference Paper Finalist at the 2022 International Conference on Advanced Robotics and Mechatronics, and the Best Paper Award at the 2023 IEEE Conference on Industrial Electronics and Applications. He served as an Associate Editor for the 2025 IFAC Symposium on Robotics.

Research Interests

Publications

12 associated published works · View on Research

Online Time-Optimal Path Parameterization With Third-Order Constraints Based on Sequential Linear Programming
Yunan Wang, Chuxiong Hu, Ran Zhou, Jichuan Yu, Shize Lin, Zeyang Li
IEEE Transactions on Industrial Informatics  ·  Sep 2026  ·  doi:10.1109/tii.2026.3688315
A Novel State-Centric Necessary Condition for Time-Optimal Control of Controllable Linear Systems Based on Augmented Switching Laws
Yunan Wang, Chuxiong Hu, Yujie Lin, Zeyang Li, Shize Lin, Suqin He
IEEE Transactions on Automatic Control  ·  Mar 2026  ·  doi:10.1109/tac.2025.3618613
Online time-optimal trajectory planning along parametric toolpaths with strict constraint satisfaction and certifiable feasibility guarantee
Yunan Wang, Chuxiong Hu, Yuanshenglong Li, Jichuan Yu, Jizhou Yan, Yixuan Liang, Zhao Jin
International Journal of Machine Tools and Manufacture  ·  Feb 2026  ·  doi:10.1016/j.ijmachtools.2025.104355
Chattering Phenomena in Time-Optimal Control for High-Order Chain-of-Integrator Systems With Full State Constraints
Yunan Wang, Chuxiong Hu, Zeyang Li, Yujie Lin, Shize Lin, Suqin He
IEEE Transactions on Automatic Control  ·  Aug 2025  ·  doi:10.1109/tac.2025.3538775
On the consistency of path smoothing and trajectory planning in CNC machining: A surface-centric evaluation
Yunan Wang, Chuxiong Hu, Zeyang Li, Zhirui He, Shiwen Lin, Yushuo Wang, Shize Lin, Jichuan Yu, Zhao Jin, Yu Zhu
Robotics and Computer-Integrated Manufacturing  ·  Apr 2025  ·  doi:10.1016/j.rcim.2024.102873
Time-Optimal Control for High-Order Chain-of-Integrators Systems With Full State Constraints and Arbitrary Terminal States
Yunan Wang, Chuxiong Hu, Zeyang Li, Shize Lin, Suqin He, Yu Zhu
IEEE Transactions on Automatic Control  ·  Mar 2025  ·  doi:10.1109/tac.2024.3455382
Optimization-based conformal path planning for in situ bioprinting during complex skin defect repair
Wenxiang Zhao, Chuxiong Hu, Yunan Wang, Shize Lin, Ze Wang, Tao Xu
Bio-Design and Manufacturing  ·  Jan 2025  ·  doi:10.1631/bdm.2300365
Safe Reinforcement Learning With Dual Robustness
Zeyang Li, Chuxiong Hu, Yunan Wang, Yujie Yang, Shengbo Eben Li
IEEE Transactions on Pattern Analysis and Machine Intelligence  ·  Dec 2024  ·  doi:10.1109/tpami.2024.3443916
Optimization-based non-equidistant toolpath planning for robotic additive manufacturing with non-underfill orientation
Yunan Wang, Chuxiong Hu, Ze Wang, Shize Lin, Ziyan Zhao, Wenxiang Zhao, Kehui Hu, Zhongyi Huang, Yu Zhu, Zhigang Lu
Robotics and Computer-Integrated Manufacturing  ·  Dec 2023  ·  doi:10.1016/j.rcim.2023.102599
A closed-loop minimally invasive 3D printing strategy with robust trocar identification and adaptive alignment
Wenxiang Zhao, Chuxiong Hu, Shize Lin, Yunan Wang, Luzheng Liu, Ze Wang, Yu Zhu, Tao Xu
Additive Manufacturing  ·  Jul 2023  ·  doi:10.1016/j.addma.2023.103701
Learning Latent Object-Centric Representations for Visual-Based Robot Manipulation
Yunan Wang, Jiayu Wang, Yixiao Li, Chuxiong Hu, Yu Zhu
2022 International Conference on Advanced Robotics and Mechatronics (ICARM)  ·  09 Jul 2022  ·  doi:10.1109/icarm54641.2022.9959551
Dynamics Learning With Object-Centric Interaction Networks for Robot Manipulation
Jiayu Wang, Chuxiong Hu, Yunan Wang, Yu Zhu
IEEE Access  ·  2021  ·  doi:10.1109/access.2021.3077117